 CASE STUDY / 001
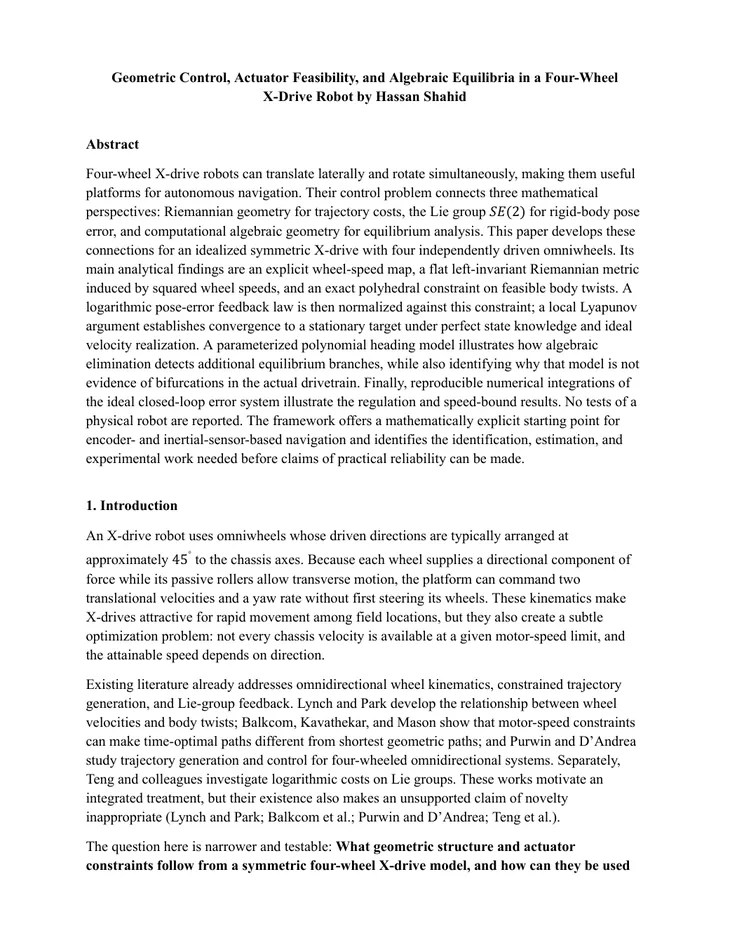
GEOMETRIC CONTROL & ACTUATOR FEASIBILITY
Developed an idealized four-wheel X-drive model connecting SE(2) pose errors, wheel-speed feasibility, Riemannian effort metrics, and equilibrium analysis. Includes numerical integration, not physical robot validation.
- ROLE
- Independent researcher / mathematical derivation
- OUTCOME
- Idealized controller and stability analysis
- ARTIFACT
- 20-page technical manuscript
- LIMIT
- Uncalibrated drivetrain; no physical test